仿生软体机器人抓手
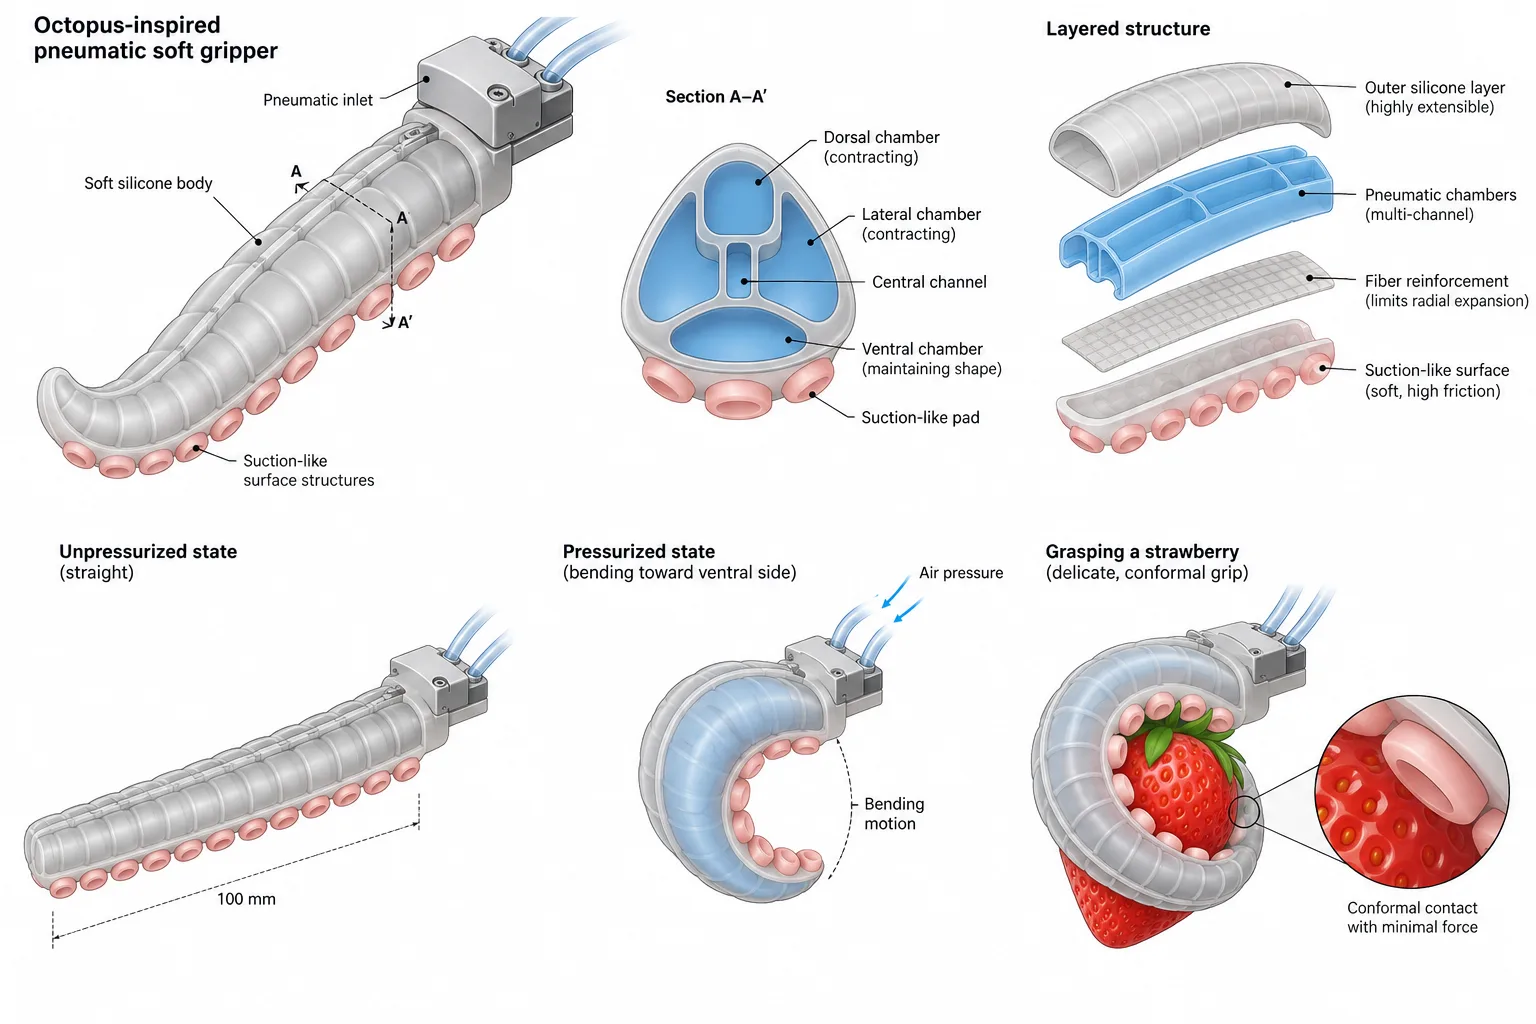
气动软体抓手的等轴设计图:气腔布局、驱动状态与抓取易碎物体的示例。
- 学科
- 物理与工程
- 风格
- 等轴立体
- 模型
- GPT Image 2.5
- 画幅比例
- 3:2
提示词
Create a publication figure in the visual style of Science Robotics: an isometric design sheet of a pneumatic soft robotic gripper inspired by an octopus arm: internal chamber layout, unpressurized vs pressurized bending states, grasping a strawberry, labeled. clean isometric vector illustration, white background, precise English labels.